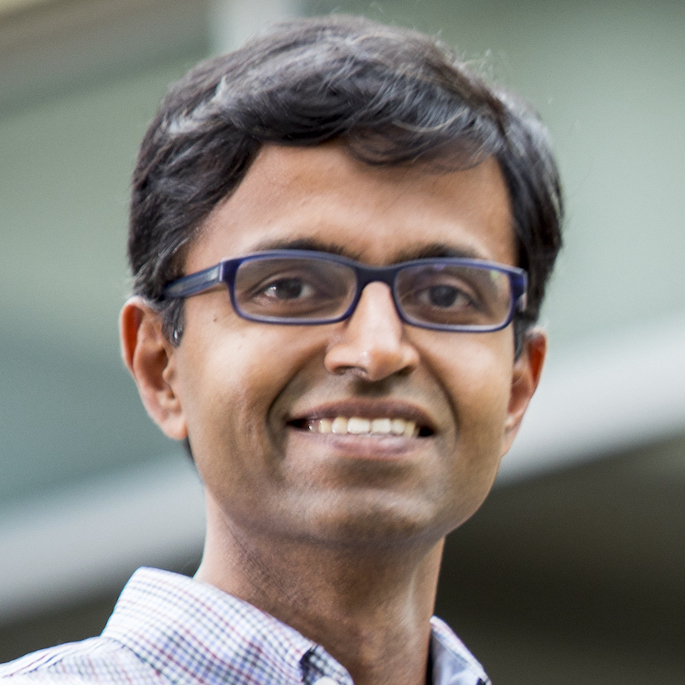
Here is my CV.
Short Bio for Seminars
Siddhartha Srinivasa is a Professor at The Paul G. Allen School of Computer Science & Engineering at the University of Washington, and an IEEE Fellow. He is a full-stack roboticist, with the goal of enabling robots to perform complex manipulation tasks under uncertainty and clutter, with and around people. To this end, he founded the Personal Robotics Lab in 2005. He is a PI on the Quality of Life Technologies NSF ERC, RCTA, DARPA ARM-S, DARPA Robotics Challenge, and DARPA RACER, and has built several robots (HERB, ADA, CHIMP, MuSHR), and has written software frameworks (OpenRAVE, DART) and best-paper award winning algorithms (CBiRRT, CHOMP, BIT*, Legibility, LazySP) used extensively by roboticists around the world. Sidd received a B.Tech in Mechanical Engineering from the Indian Institute of Technology Madras in 1999, and a PhD in 2005 from the Robotics Institute at Carnegie Mellon University. He played badminton and tennis for IIT Madras, captained the CMU squash team, ran long-distance competitively, and lately plays tennis.
Awards
| Year(s) | Award | Conference | Paper |
|---|---|---|---|
| 2026 | Test of Time Award | ACM/IEEE International Conference on Human-Robot Interaction | Legibility and predictability of robot motion |
| 2025 | RSS-ROAR Workshop Best Paper Award Winner | Conference on Robot Learning | Long Range Navigator (LRN) : Extending robot planning horizons beyond metric maps |
| 2025 | Best Paper Award Finalist for Systems | ACM/IEEE International Conference on Human-Robot Interaction | Lessons Learned from Designing and Evaluating a Robot-assisted Feeding System for Out-of-lab Use |
| 2024 | Best Demo Award Winner | ACM/IEEE International Conference on Human-Robot Interaction | An Adaptable, Safe, and Portable Robot-Assisted Feeding System |
| 2023 | Top 5 Percent Paper | International Conference on Learning Representations | Git Re-Basin: Merging models modulo permutation symmetries |
| 2023 | Best Paper Award Winner for Design | ACM/IEEE International Conference on Human-Robot Interaction | Design Principles for Robot-Assisted Feeding in Social Contexts |
| 2019 | Best Student Paper Award Winner | International Conference on Automated Planning and Scheduling | Generalized Lazy Search for Robot Motion Planning: Interleaving Search and Edge Evaluation via Event-based Toggles |
| 2019 | Best Paper Award Winner for Technical Advances in HRI | ACM/IEEE International Conference on Human-Robot Interaction | Transfer depends on Acquisition: Analyzing Manipulation Strategies for Robotic Feeding |
| 2018 | IEEE Fellow | ||
| 2018 | Best Paper Award Finalist | ACM/IEEE International Conference on Human-Robot Interaction | Planning with Trust for Human-Robot Collaboration |
| 2018 | Best Paper Award Winner | International Conference on Automated Planning and Scheduling | The Provable Virtue of Laziness in Motion Planning |
| 2018 | Best Demo Award Winner | Conference on Neural Information Processing Systems | Autonomous robot feeding for upper-extremity mobility impaired people: Integrating sensing, perception, learning, motion planning, and robot control |
| 2017-23 | Boeing Endowed Professorship in Computer Science | ||
| 2017 | CMU Women’s Association outstanding graduating senior advisor (Rachel Holladay) | ||
| 2016 | Best Vision Paper Award Finalist | IEEE International Conference on Robotics and Automation | Articulated Robot Manipulator Simultaneous Localization and Mapping (ARM-SLAM) |
| 2015 | Best Systems Paper Award Finalist | Robotics: Science and Systems | CHISEL: Real Time Large Scale 3D Reconstruction Onboard a Mobile Device |
| 2015 | Best Conference Paper Award Finalist | IEEE International Conference on Robotics and Automation | Movement Primitives via Optimization |
| 2014 | Best Video Award Finalist | IEEE International Conference on Robotics and Automation | Extrinsic Dexterity: In-Hand Manipulation with External Forces |
| 2013-16 | Finmeccanica Chair in Computer Science | ||
| 2013 | RSS Early Career Spotlight Award | ||
| 2013 | Best Manipulation Paper Award Finalist | IEEE International Conference on Robotics and Automation | Efficient Touch Based Localization through Submodularity |
| 2013 | Best Paper Award Finalist | Robotics: Science and Systems | Generating Legible Motion |
| 2012 | Robotics Institute Cool Person of the Year Award | ||
| 2012 | Okawa Foundation Research Grant | ||
| 2012 | Office of Naval Research Young Investigator Award | ||
| 2012 | Best Paper Award Finalist | Robotics: Science and Systems | Formalizing Assistive Teleoperation |
| 2012 | Best Paper Award Finalist | IEEE International Symposium on Robot and Human Interactive Communication | Online Customization of Teleoperation Interfaces |
| 2011 | RAS Most Active Technical Committee Award: Mobile Manipulation | ||
| 2010 | Best Paper Award Finalist | IEEE/RSJ International Conference on Intelligent Robots and Systems | Push-grasping with dexterous hands: Mechanics and a method |
| 2010 | Best Paper Award Winner | ACM/IEEE International Conference on Human-Robot Interaction | Gracefully mitigating breakdowns in robotic services |
| 2010 | Best Manipulation Paper Award Finalist | IEEE International Conference on Robotics and Automation | Planning pre-grasp manipulation for transport tasks |
| 2009 | Best Vision Paper Award Finalist | IEEE International Conference on Robotics and Automation | Object recognition and full pose registration from a single image for robotic manipulation |
| 2008 | Intel Corporate Technology Group Divisional Recognition Awards | ||
| 2006-07 | Intel Research Pittsburgh Lab Research Awards | ||
| 1997-98 | Jawaharlal Nehru Summer Research Fellowship, Indian Institute of Science | ||
| 1997-98 | Rajiv Gandhi Award for Best Summer Research Fellow, Indian Institute of Science | ||
| 1994 | Indian National Mathematics Olympiad |